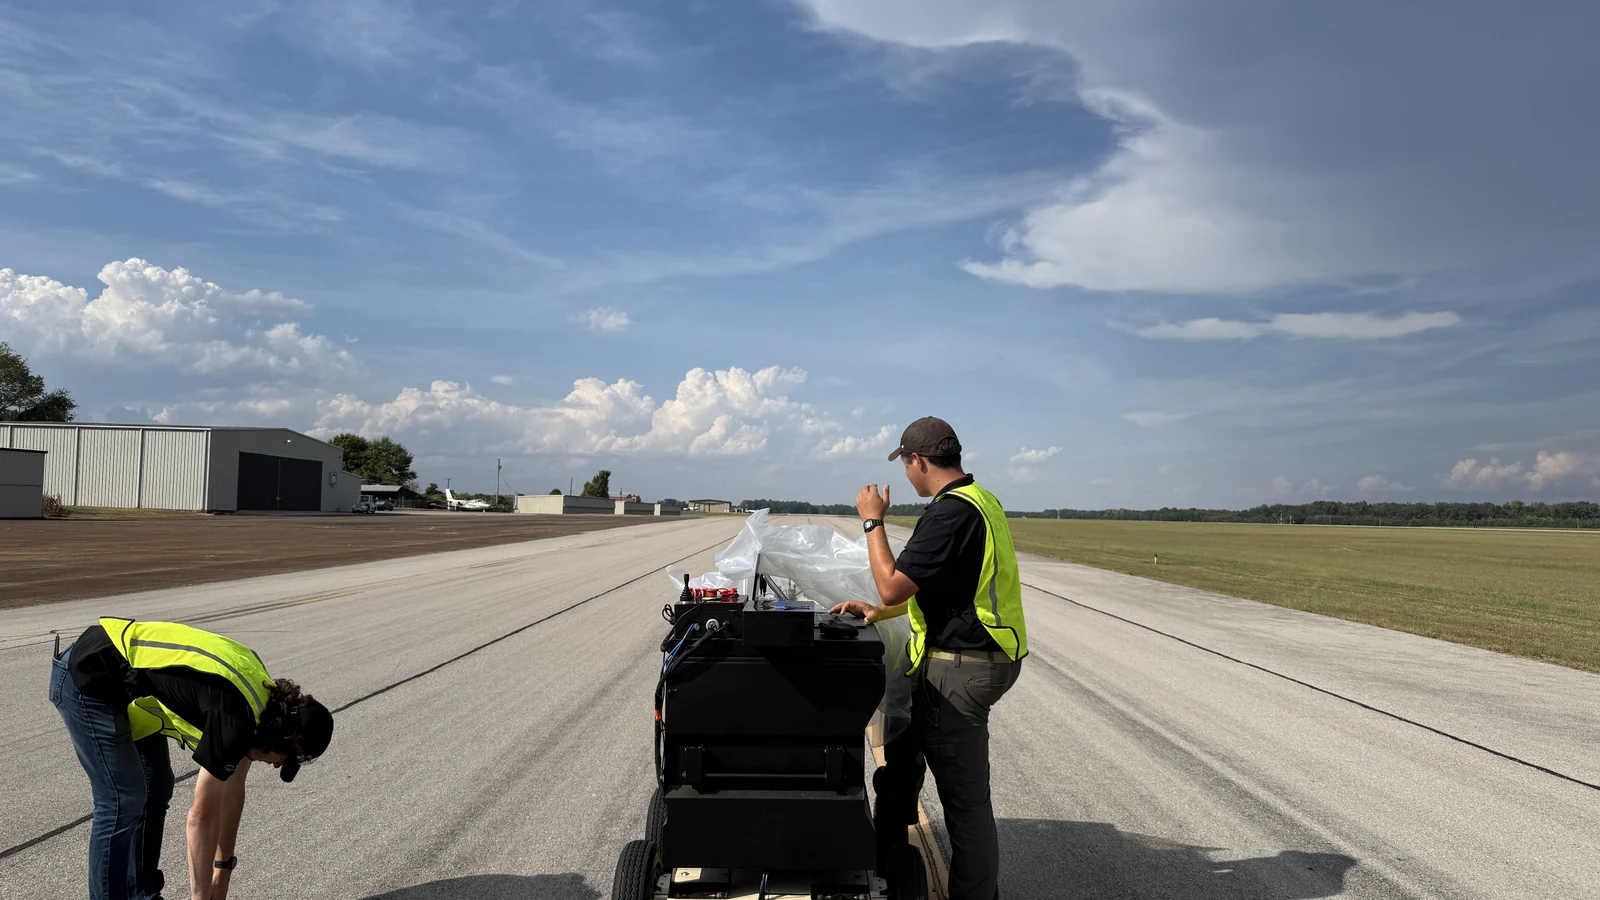
Inertial-Guided Autonomous Mobility
GPS-denied and vision-less autonomous rover for operationally secure flightline logistics and maintainer equipment transport.
GPS-denied and vision-less autonomous rover for operationally secure flightline logistics and maintainer equipment transport.
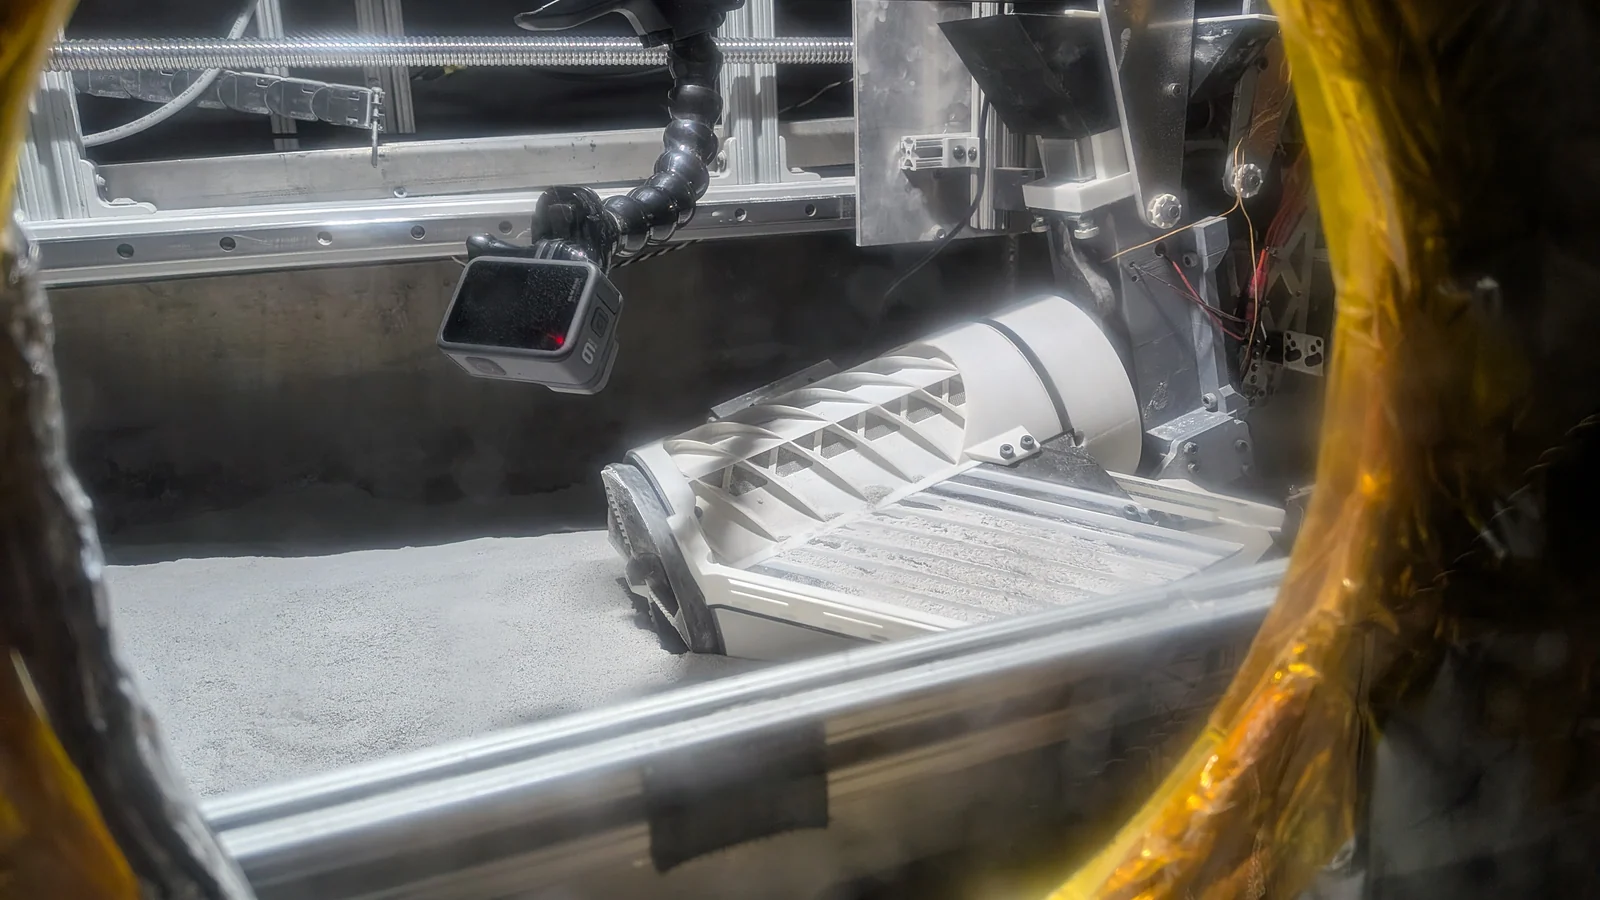
Robotic processing and stabilization of bulk regolith to support Moon Base exploration, logistics, and habitat infrastructure. Partner: Michigan Tech
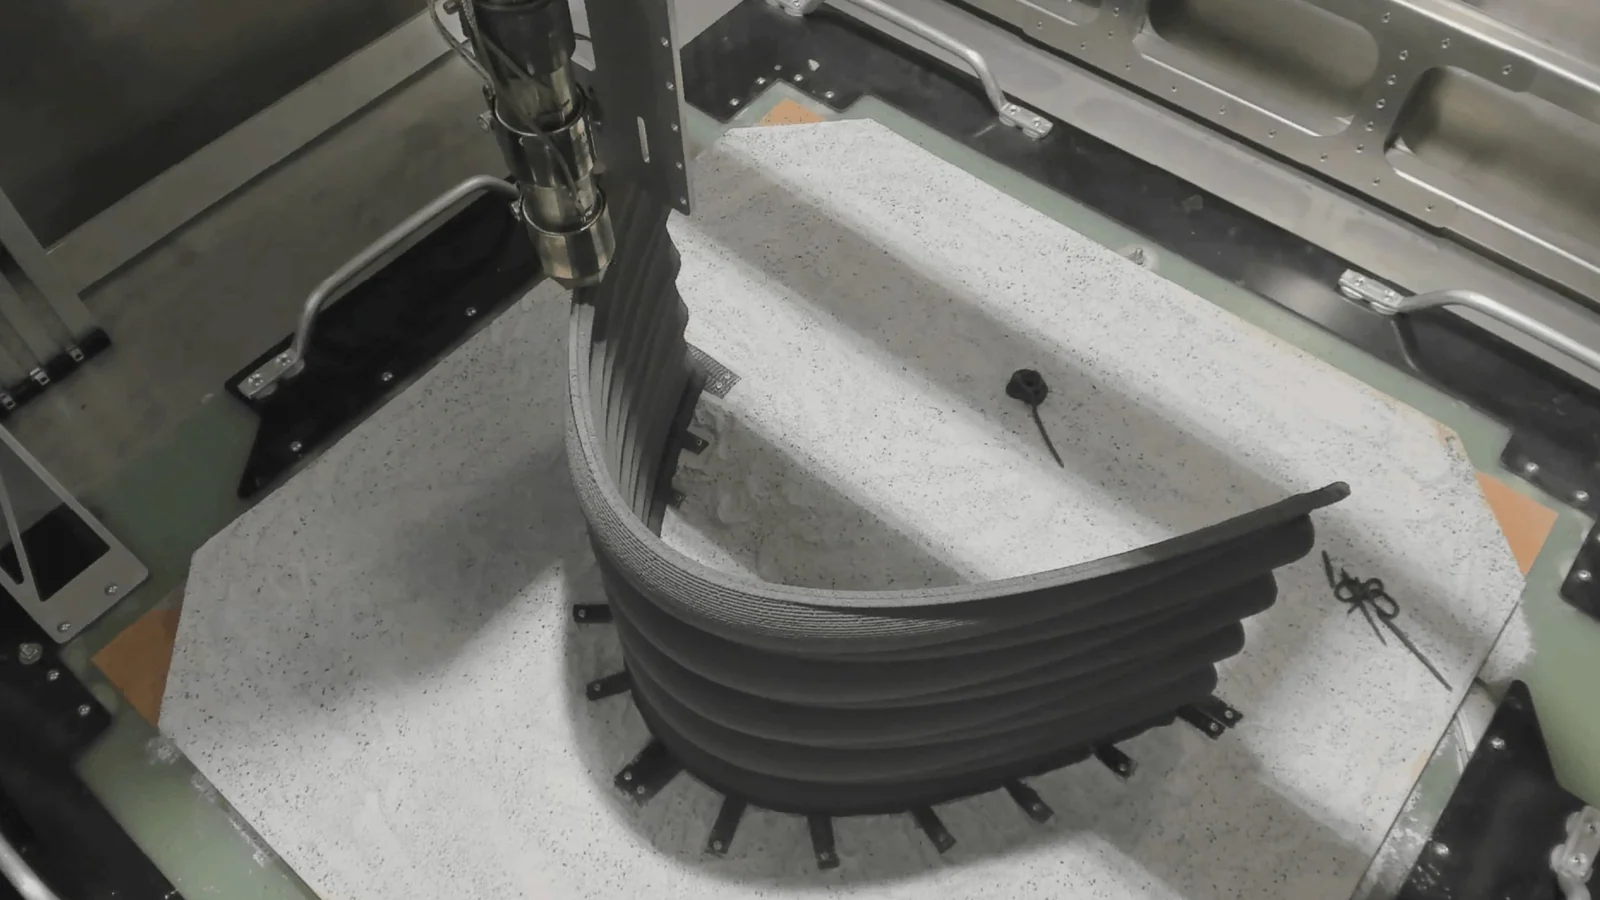
Advancing additive construction technology using regolith-polymer composite materials in lunar-like cryogenic vacuum conditions.
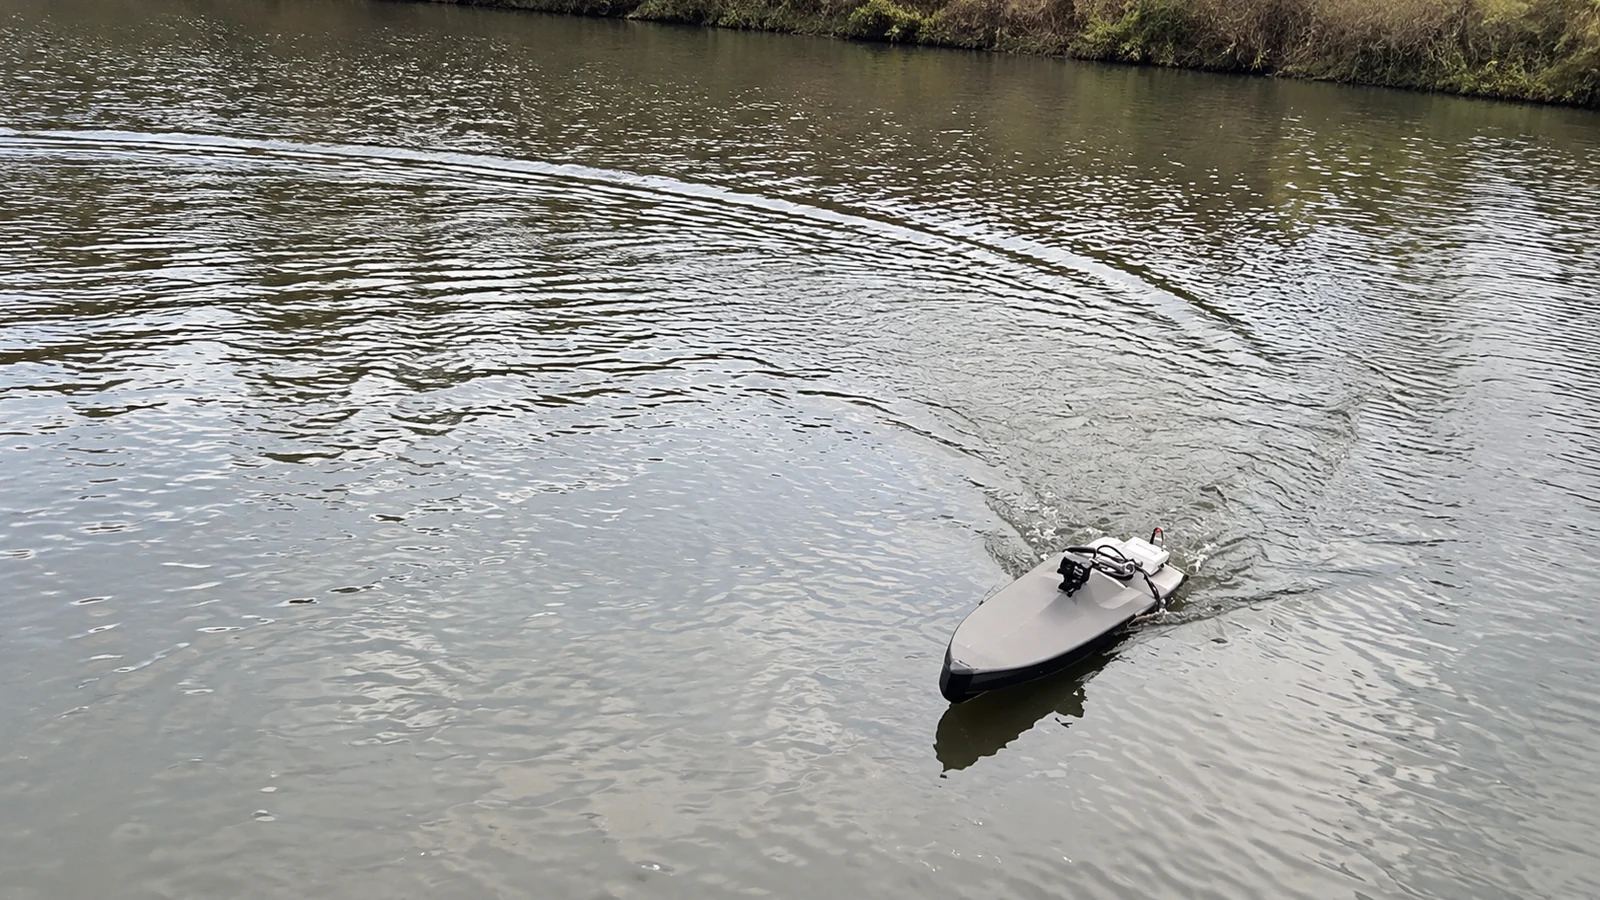
Mobile manufacturing platforms and rapid point-of-need manufacturing approaches for austere and expeditionary environments.
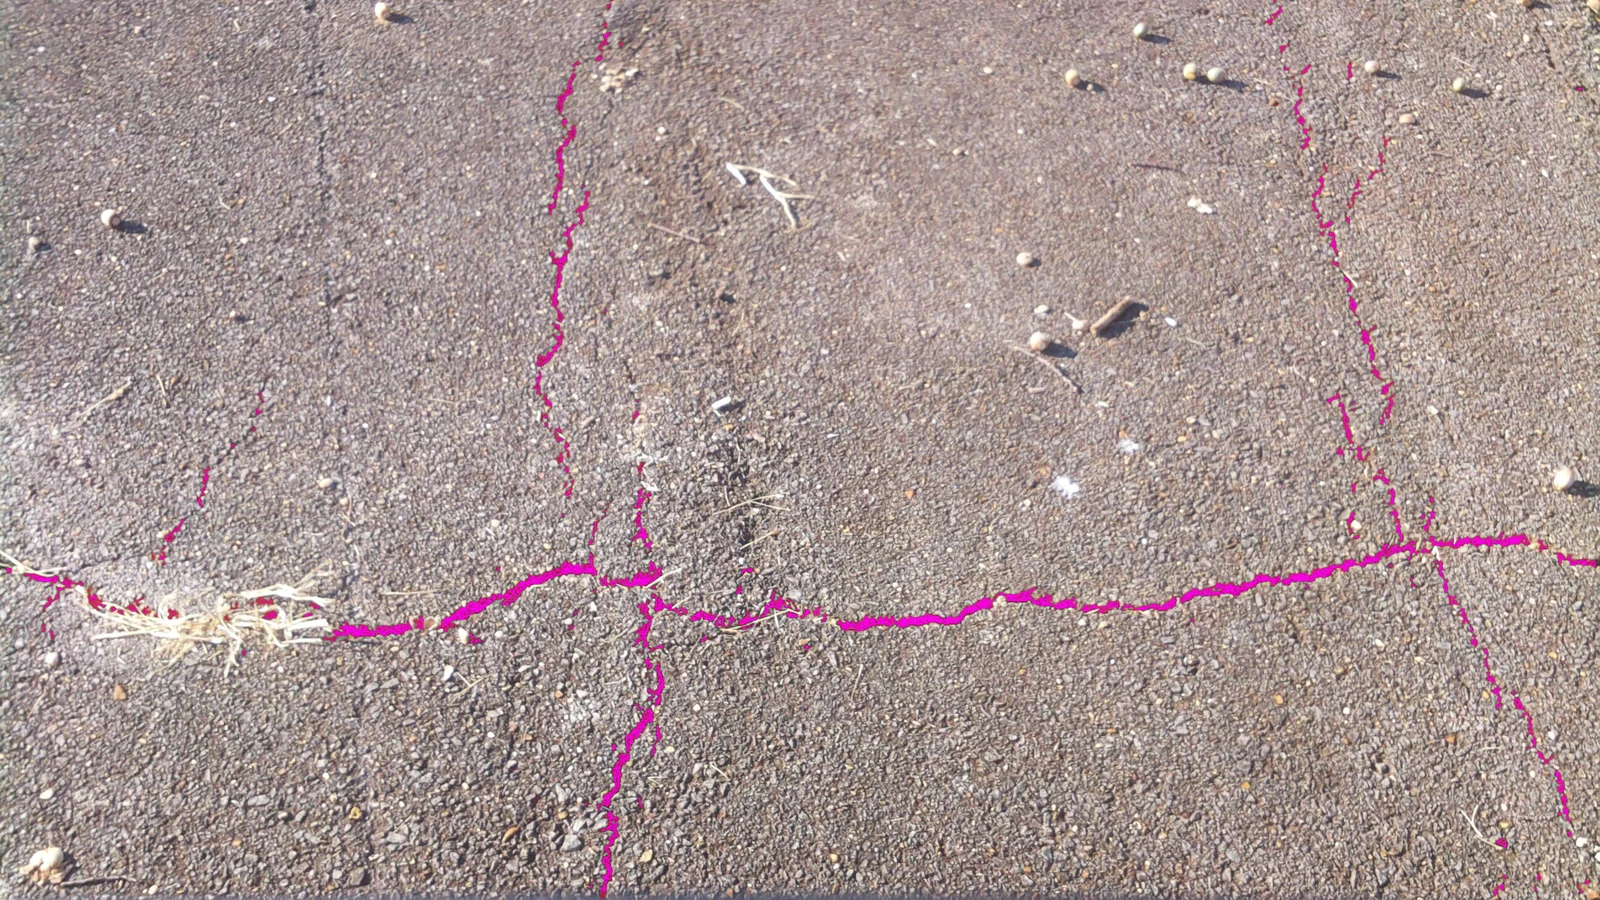
Vehicle-mounted computer vision and AI/ML models for automated airfield pavement classification and foreign object debris (FOD) detection.
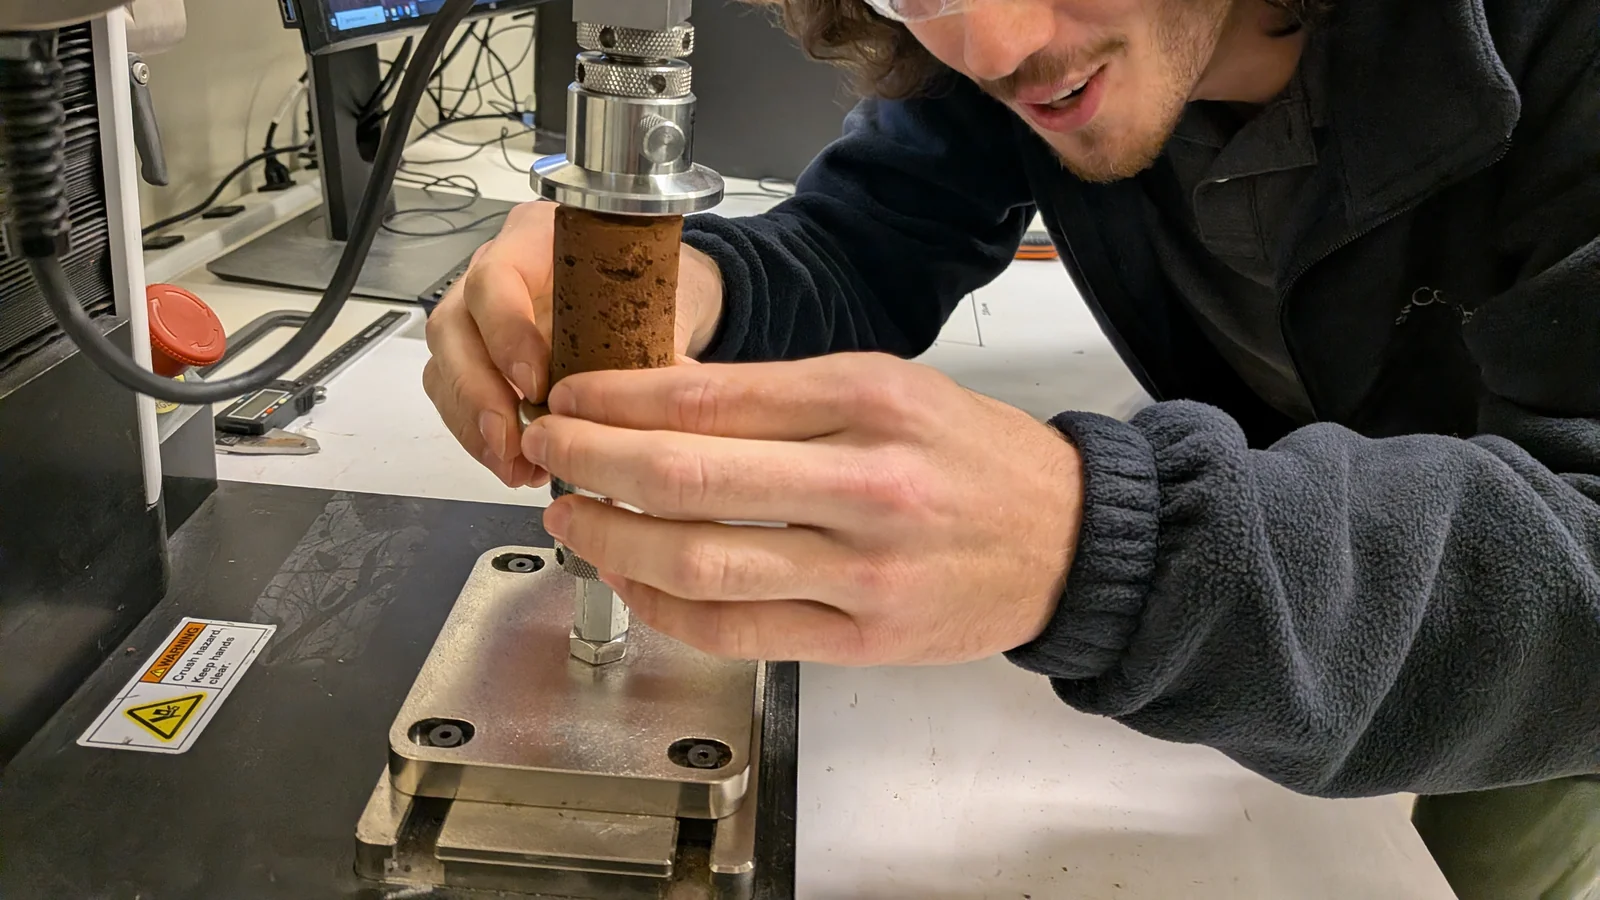
Locally sourced mineral and waste-derived feedstocks for durable, resource-efficient road surfaces.
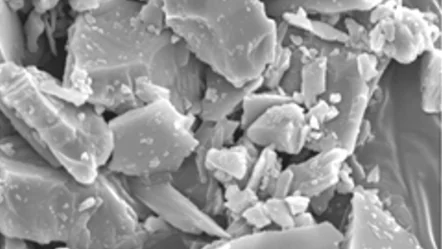
Miicrobial consortia and ISRU feedstocks for biomaterial synthesis and in-space manufacturing, in collaboration with Dr. Rebecca Prescott.
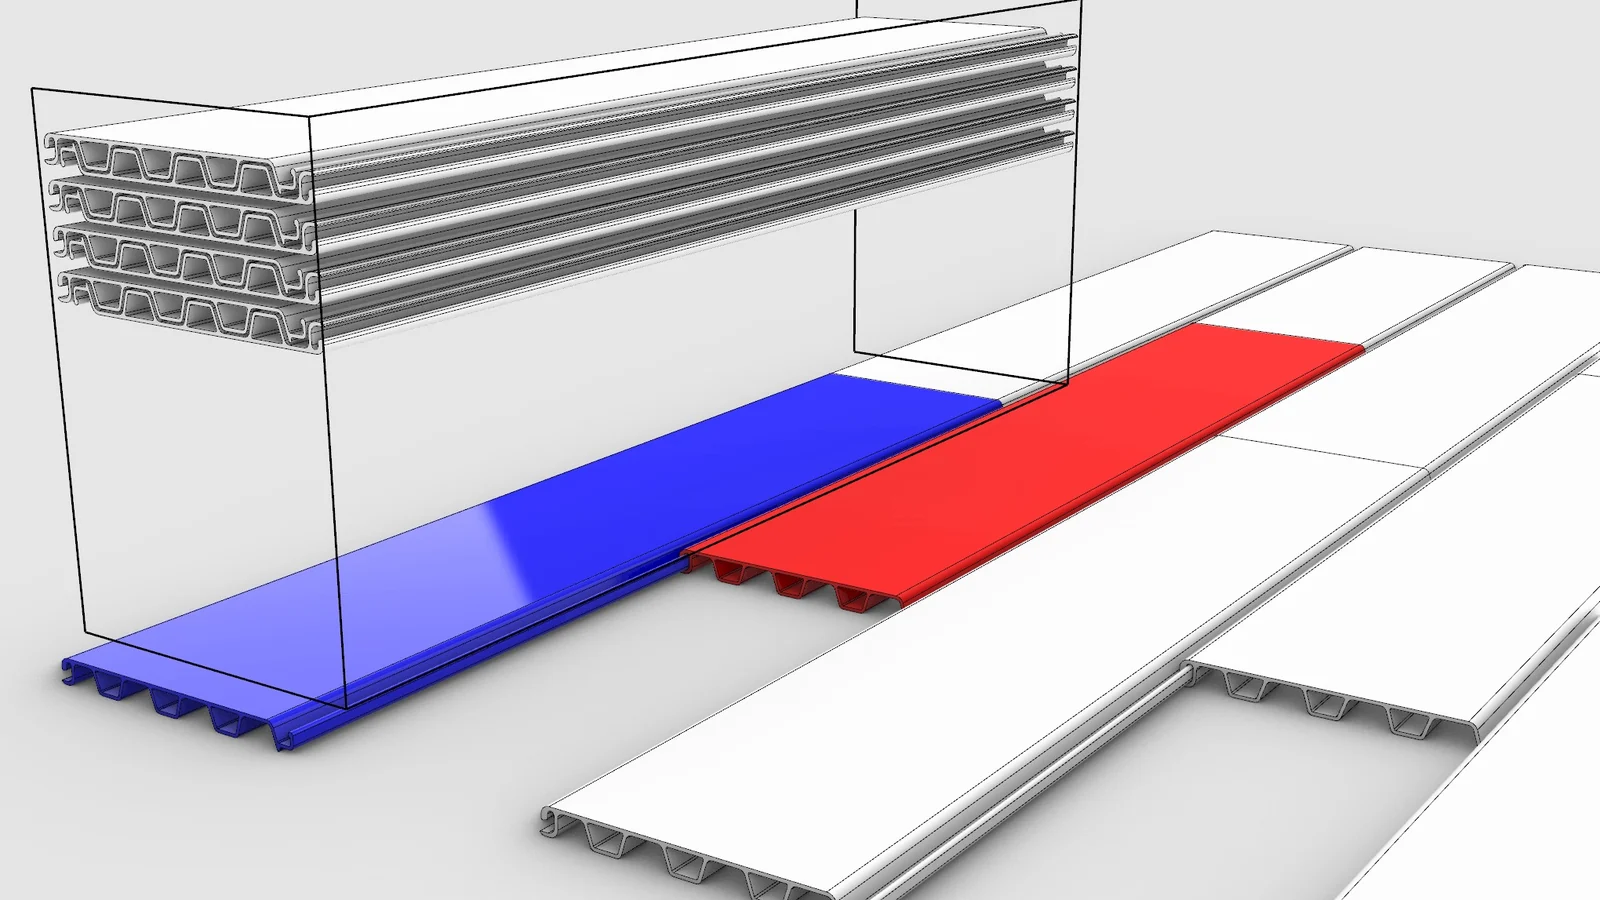
Robotic placement of interlocking prefabricated aluminum panels for rapid expeditionary airfield deployment.
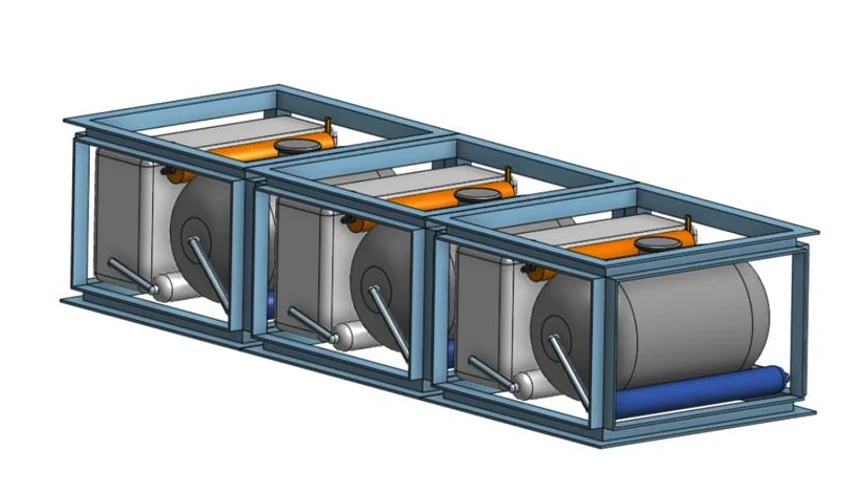
Cryogenic liquid hydrogen storage and delivery systems for improved endurance, range, and power in unmanned aerial systems.
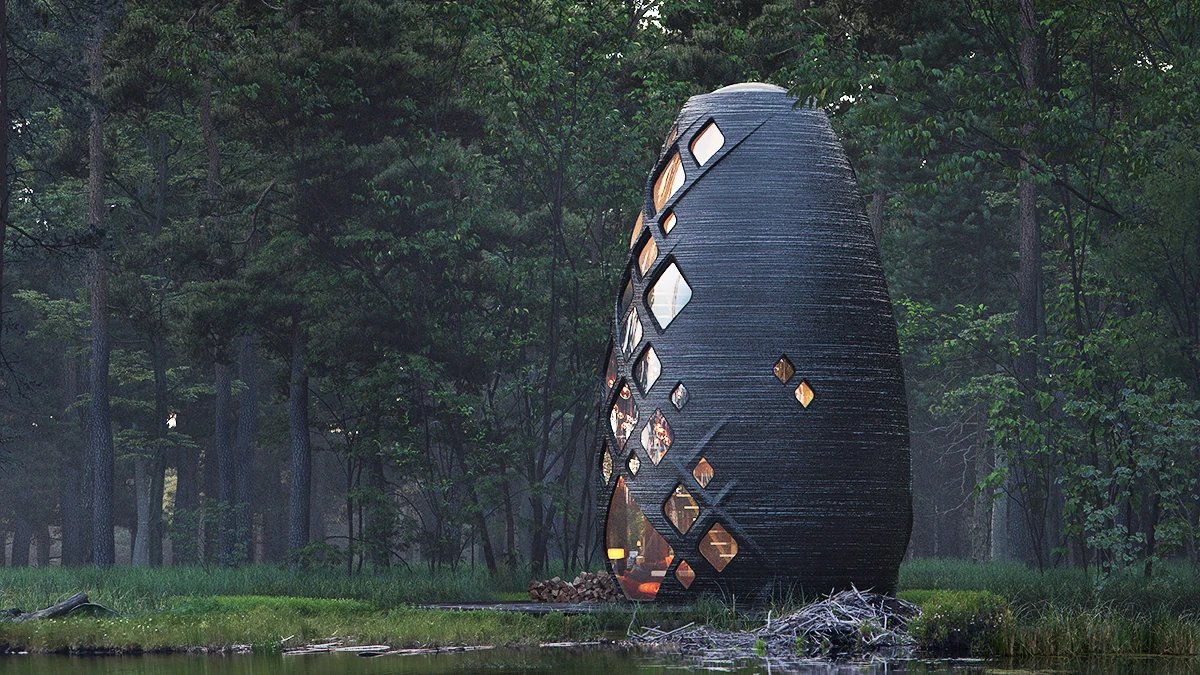
Earth-based habitat demonstrator exploring the terrestrial application of space-derived construction technology.
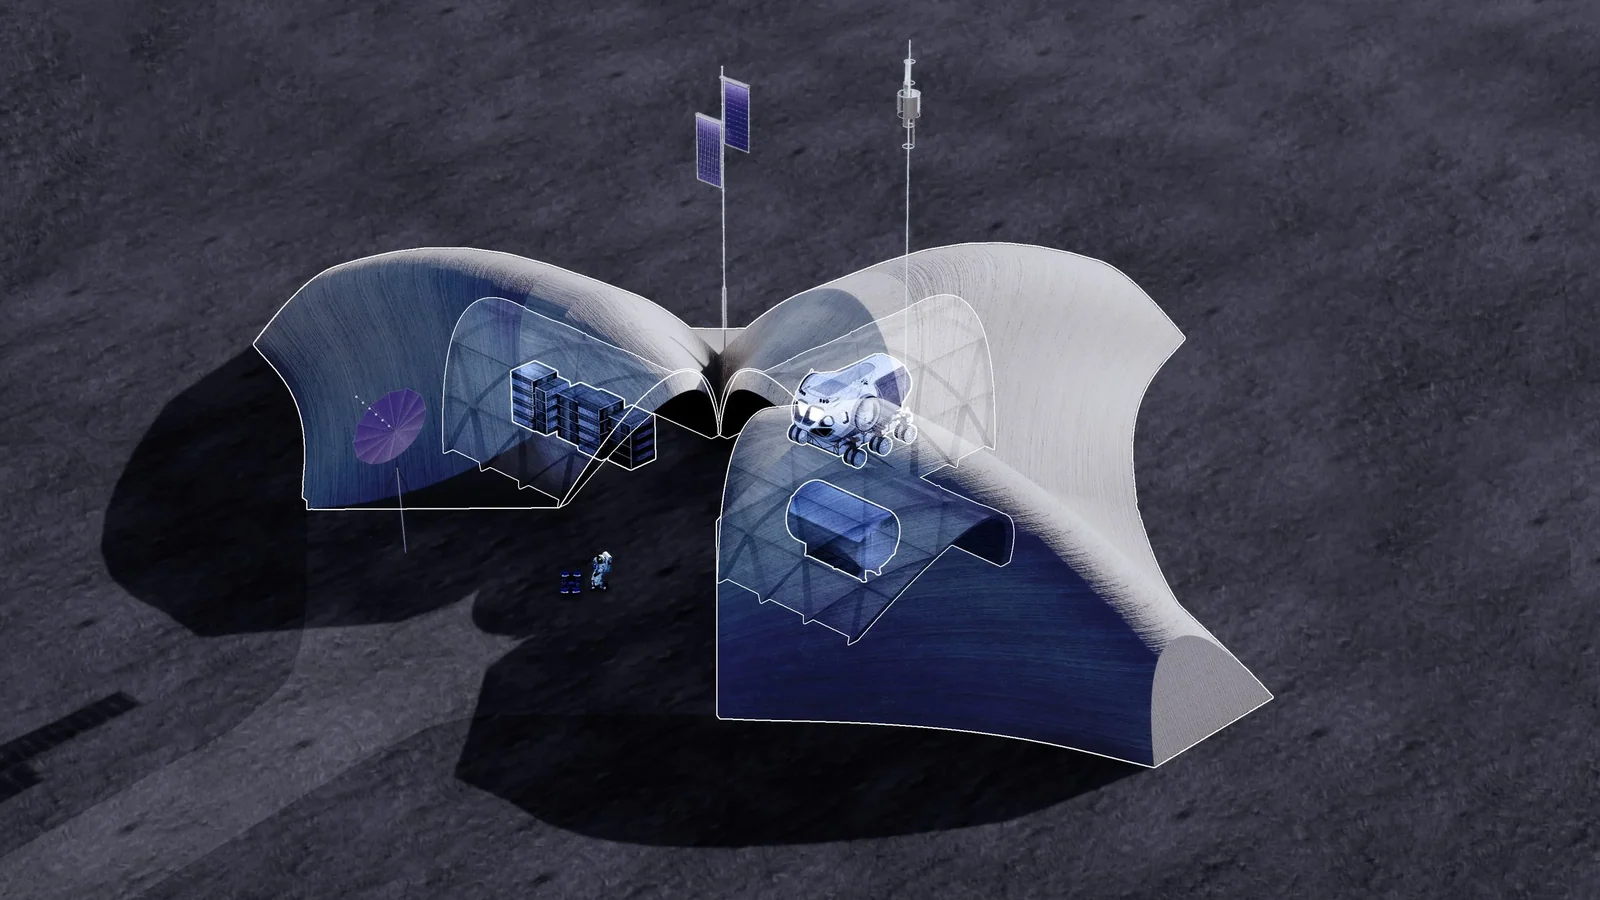
Design and engineering of a 3D printed regolith overburden shelter for radiation, thermal, and micrometeoroid protection.
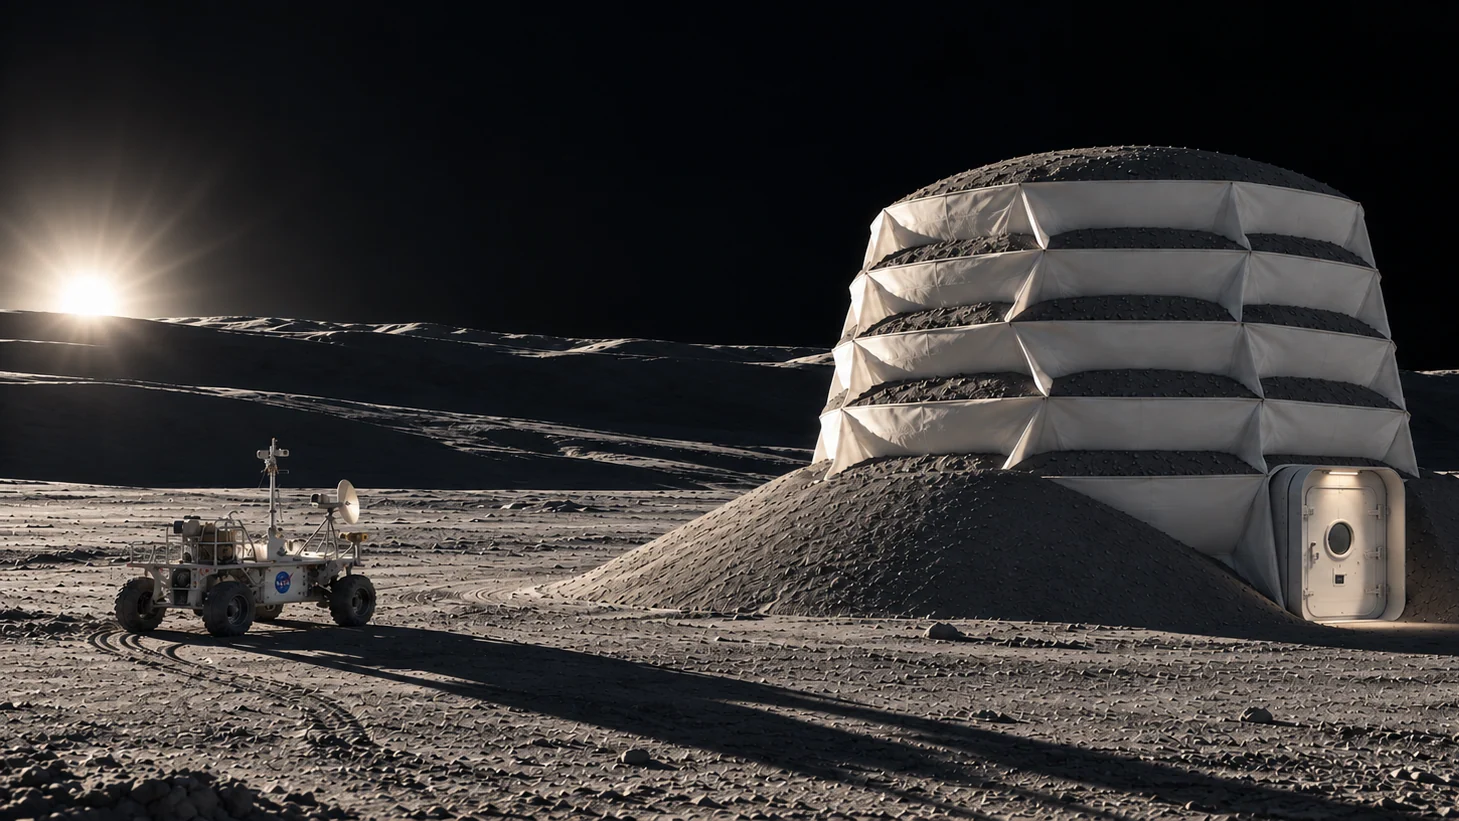
Inflatable softgoods habitat research using a staged inflation process to emplace regolith overburden for radiation shielding.
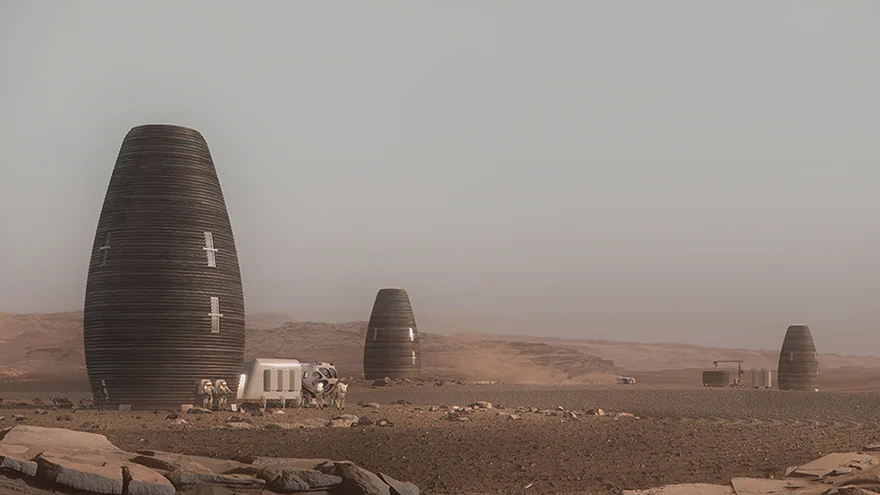
Award-winning Mars habitat concept and large-scale robotic 3D-printing demonstration developed for NASA’s 3D-Printed Habitat Challenge.